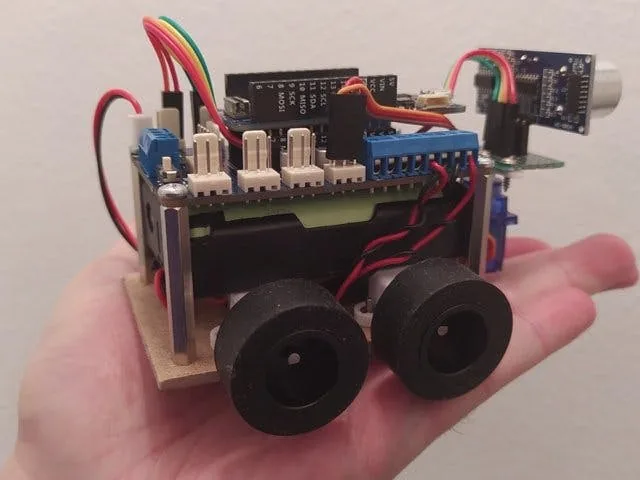
Motor Selection Guide
Motor selection starts with load, motion, duty cycle, and environment, then moves to gearing, driver, and supply.
Knowledge Center
Motor selection starts with load, motion, duty cycle, and environment, then moves to gearing, driver, and supply.
An IoT system is more than a connected device; it spans identity, connectivity, data, security, updates, and monitoring.
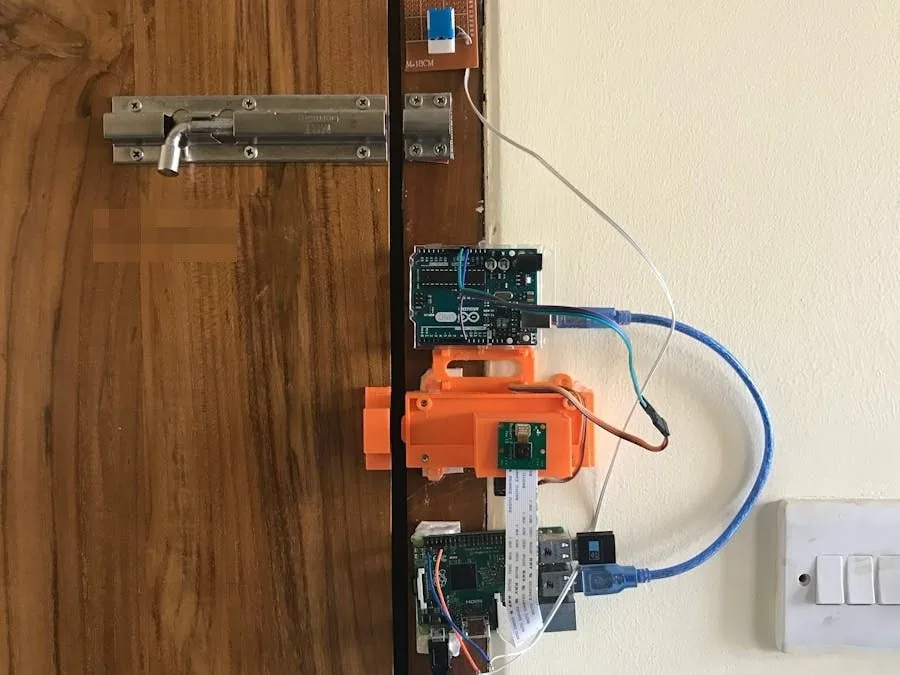
Embedded systems perform defined functions under resource, power, and timing limits, so success depends on explicit constraints from the start.
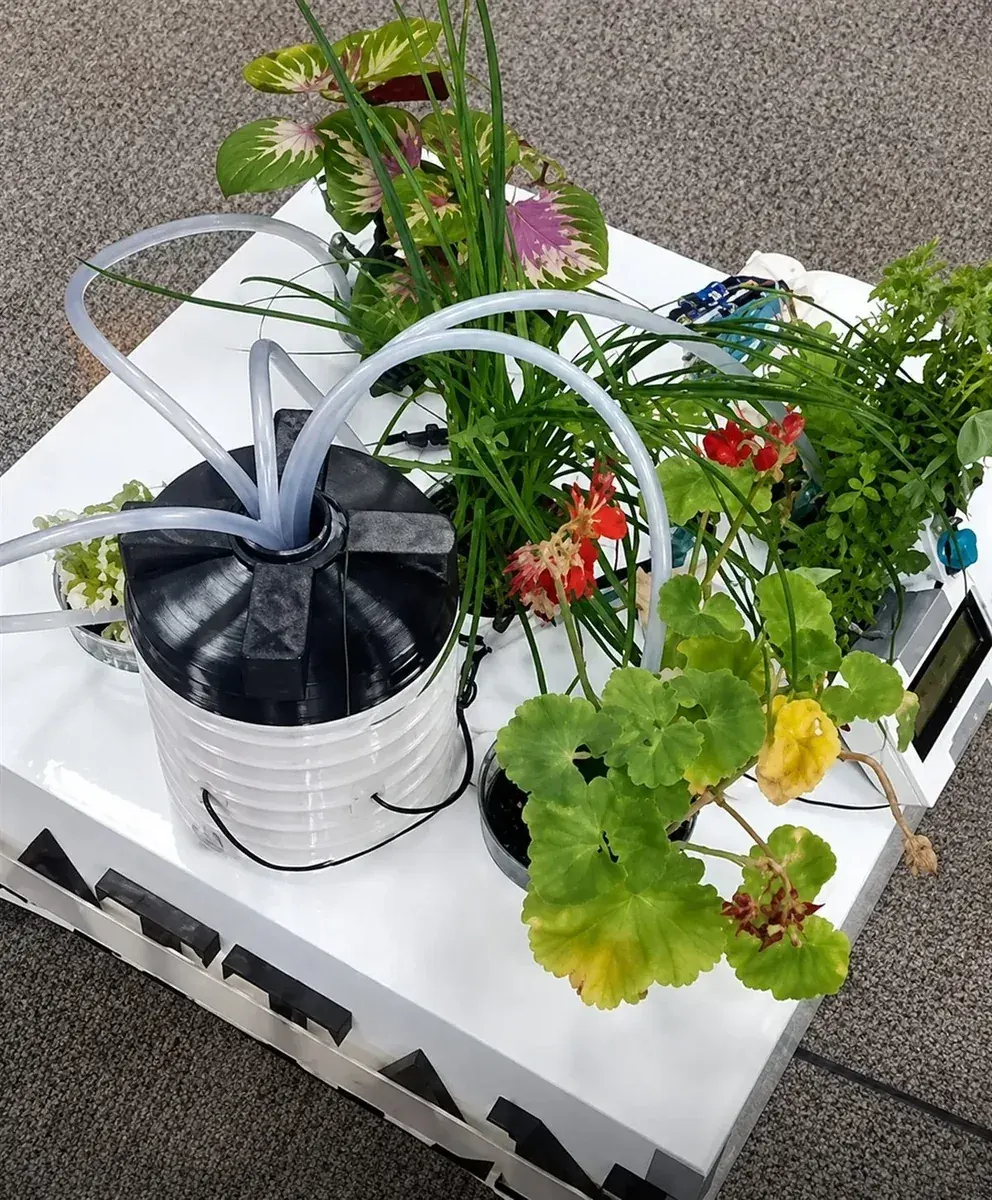
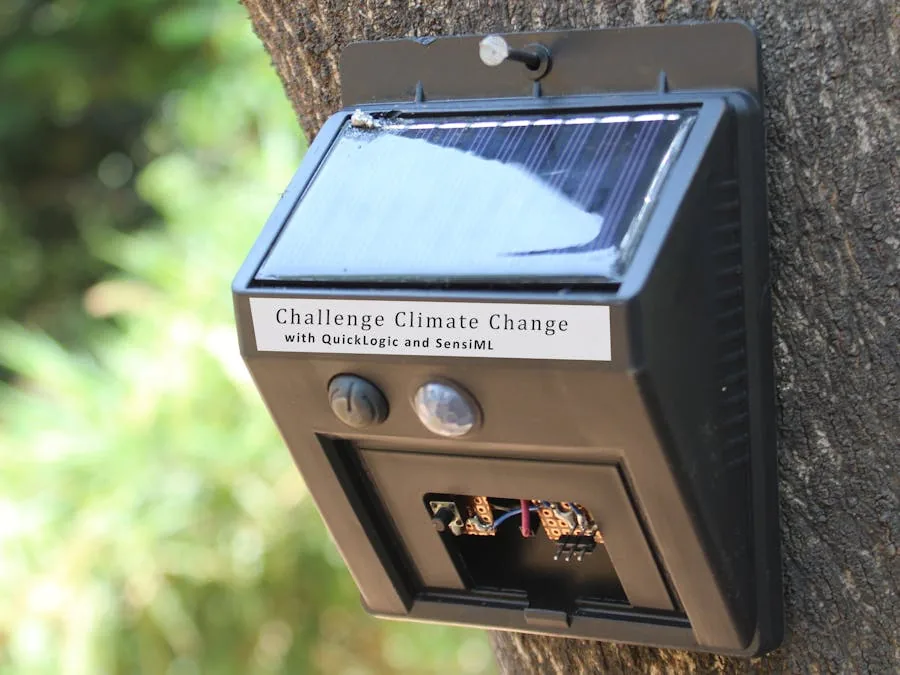
This case shows how an environmental monitoring need becomes reliable sensing, local control, and observable connectivity.
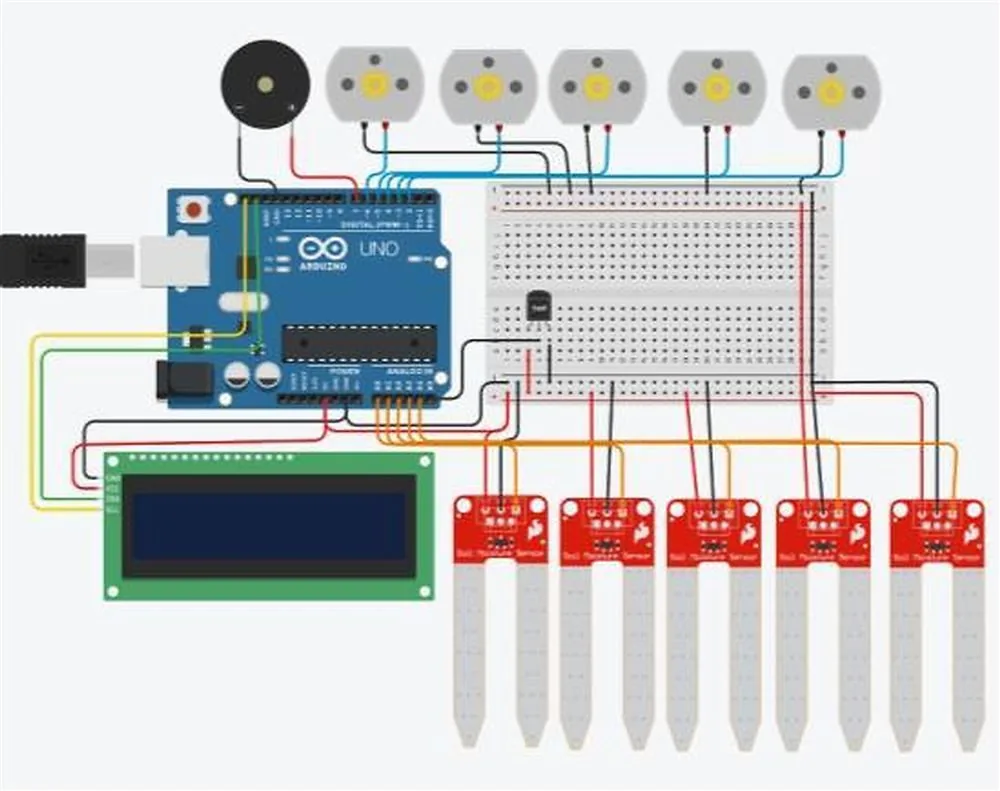
Digital manufacturing shortens iteration when revisions, tolerances, and production instructions remain traceable.
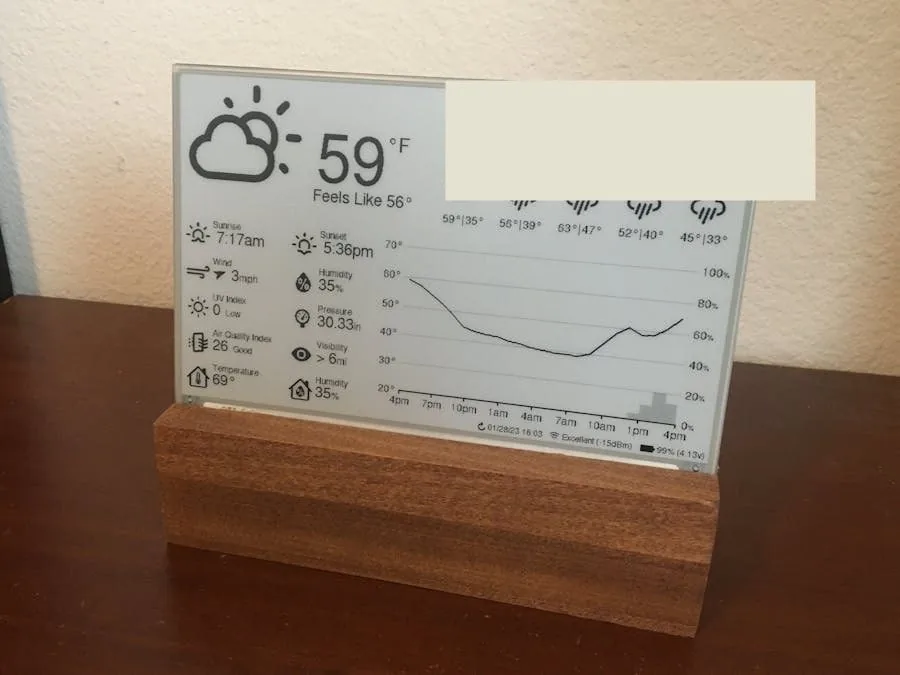
Low power comes from a clear budget for every operating state plus suitable network, sensors, and transmission cadence.
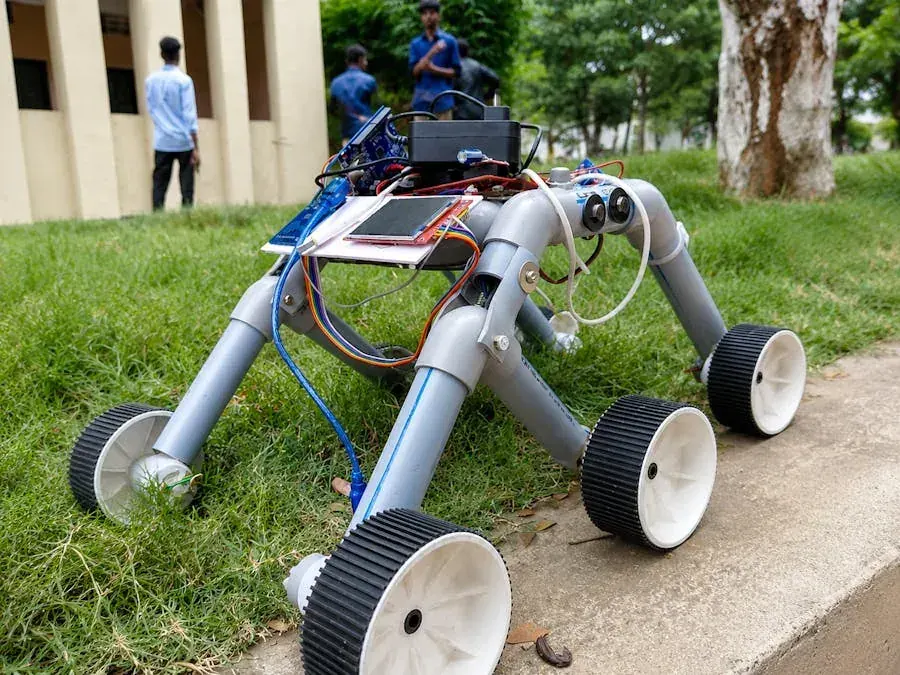
Raspberry Pi is effective for vision and interfaces but requires design for boot time, storage, and non-deterministic timing.
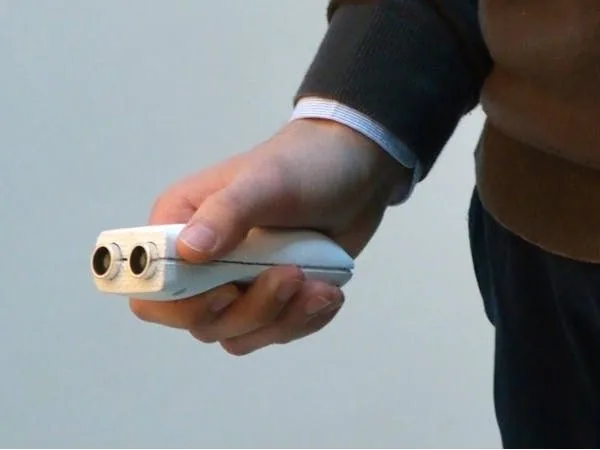
Visual inspection succeeds through defect definition, lighting, data, and error cost before model selection.
DFAM rethinks parts for consolidation, lightweighting, and customization while controlling orientation, supports, and tolerances.