What was the challenge?
Connect visual identification of Jenga blocks with robotic handling.
JBot links computer vision with the physical handling of Jenga blocks, from identification to extraction and rearrangement. The concept makes the perception-to-action sequence concrete, without claiming a measured success rate or validated autonomous performance. This item appears in the portfolio under Robotics, with its documented challenge, solution and output presented on the page.
Discuss a similar project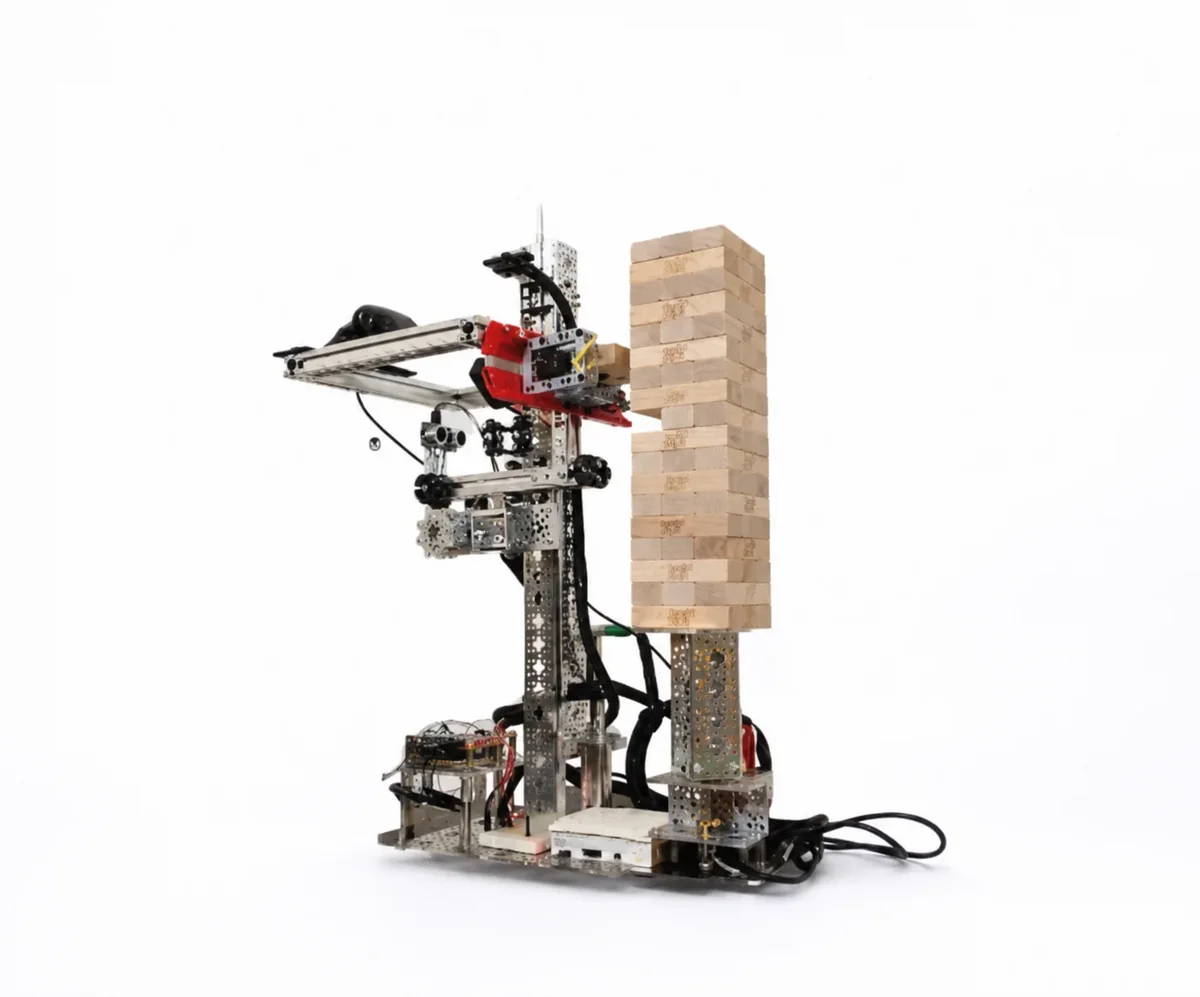
Connect visual identification of Jenga blocks with robotic handling.
JBot links computer vision with the physical handling of Jenga blocks, from identification to extraction and rearrangement. The concept makes the perception-to-action sequence concrete, without claiming a measured success rate or validated autonomous performance.
A JBot concept using computer vision to handle Jenga blocks.
Custom motion, control, and sensing prototypes for research, education, and industrial concept validation.
View detailsSend a structured brief so we can review the right path before sensitive details are shared.