What was the challenge?
Control a compact arm using stepper motors.
This compact arm pairs ESP32 with stepper motors for movement control. It highlights the controller’s role in organizing motor motion, without translating the design description into an unsupported accuracy or speed specification. This item appears in the portfolio under Robotics, with its documented challenge, solution and output presented on the page.
Discuss a similar project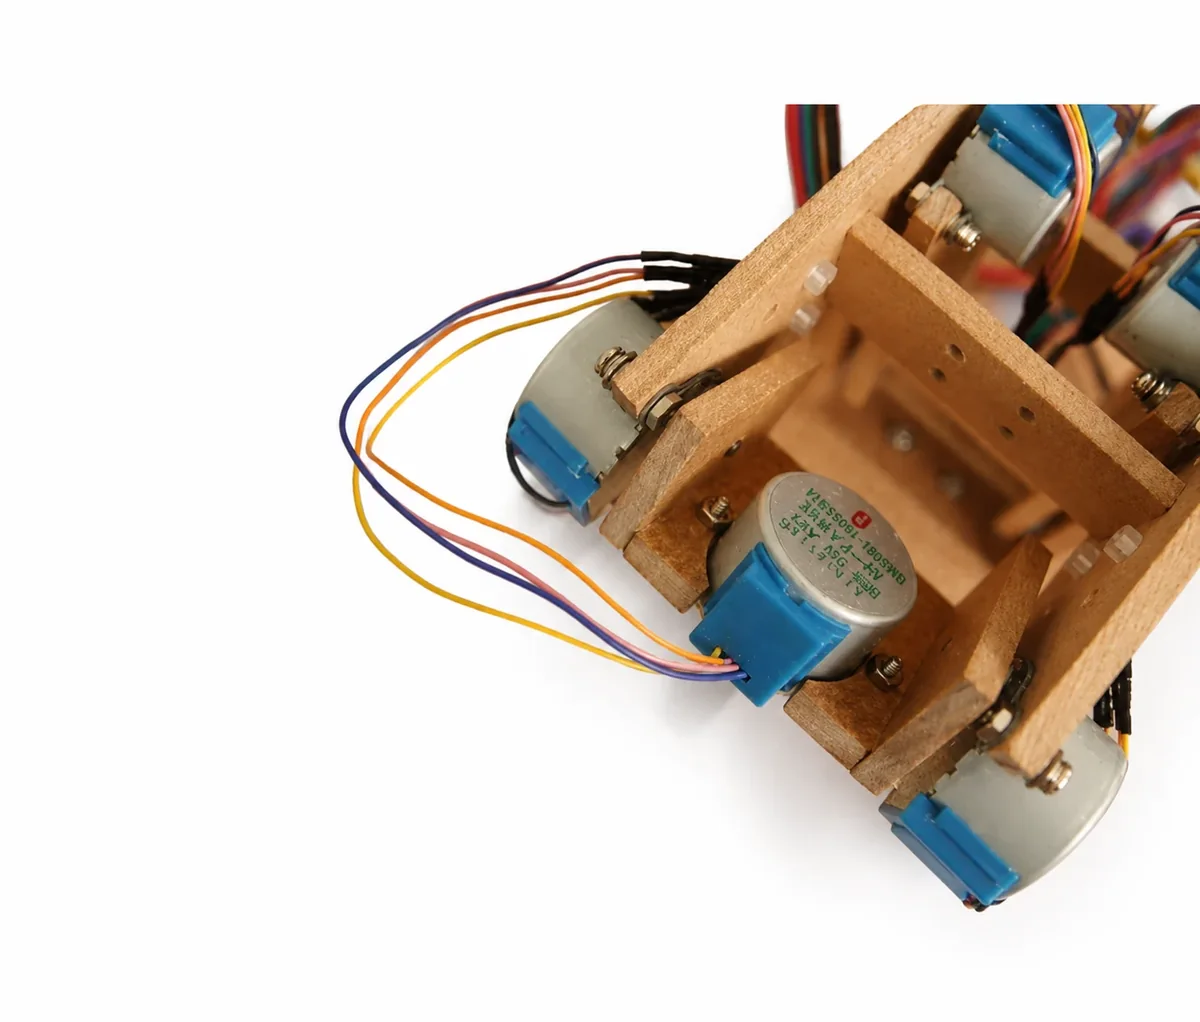
Control a compact arm using stepper motors.
This compact arm pairs ESP32 with stepper motors for movement control. It highlights the controller’s role in organizing motor motion, without translating the design description into an unsupported accuracy or speed specification.
A compact stepper-motor arm with ESP32 control.
Circuits, controllers, sensors, and connectivity for measurable smart prototypes.
View detailsCustom motion, control, and sensing prototypes for research, education, and industrial concept validation.
View detailsSend a structured brief so we can review the right path before sensitive details are shared.