What was the challenge?
Study balanced stepping in a two-legged model.
This simplified servo-driven biped introduces the coordination involved in balanced stepping.
Request a project slot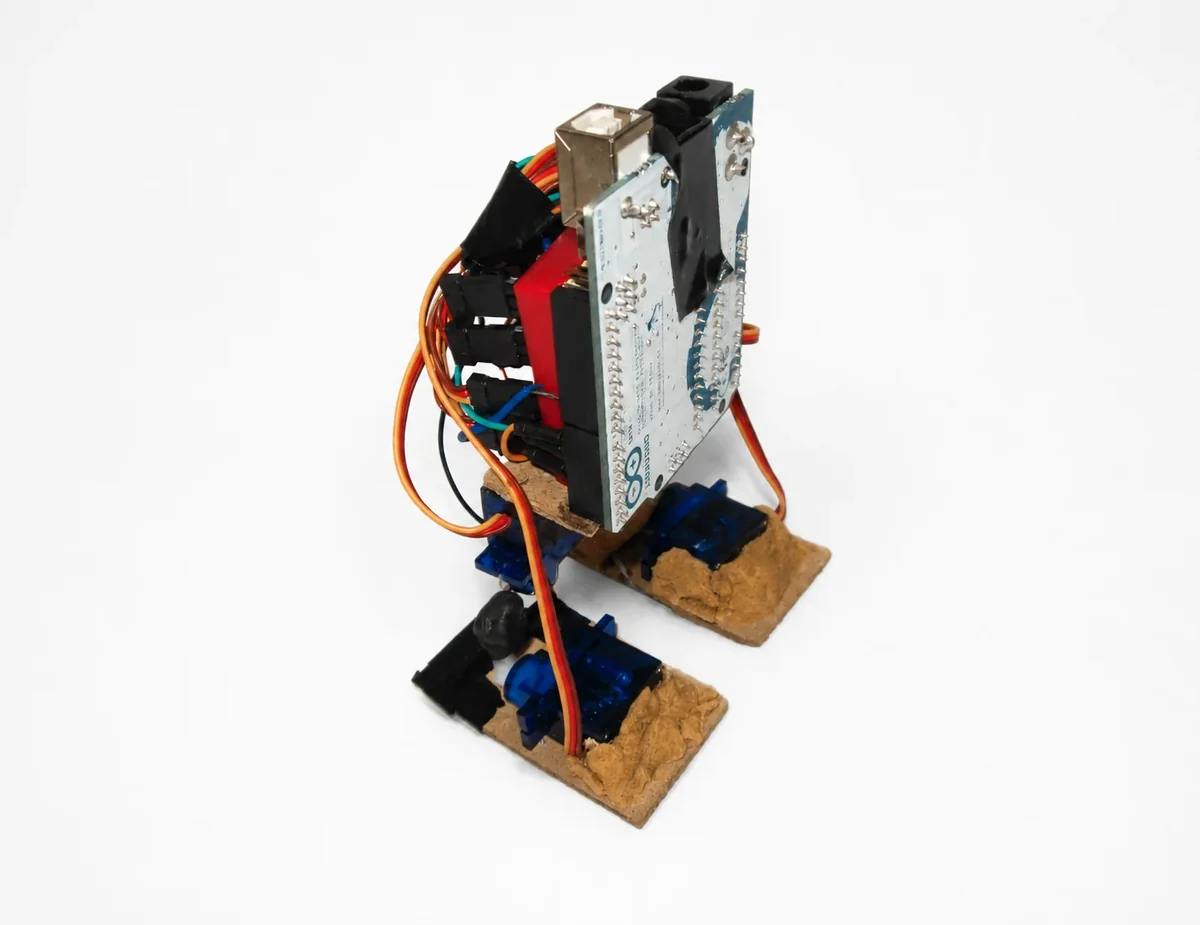
Study balanced stepping in a two-legged model.
This simplified servo-driven biped introduces the coordination involved in balanced stepping. The focus is joint motion within a two-legged structure; actual stability and walking capability remain matters for testing rather than assumed outcomes.
A simplified humanoid model driven by servo motors.
Custom motion, control, and sensing prototypes for research, education, and industrial concept validation.
View detailsHands-on programs in design, digital fabrication, electronics, and robotics built around a clear outcome.
View detailsSend a structured brief so we can review the right path before sensitive details are shared.