What was the challenge?
Provide a large hexapod platform for motion and robotics experiments.
This large Freenove hexapod provides a Raspberry Pi platform for motion and control experiments. It supports exploration of multi-legged robotics, treating movement stability as something to evaluate rather than a quantified performance claim. This item appears in the portfolio under Robotics, with its documented challenge, solution and output presented on the page.
Discuss a similar project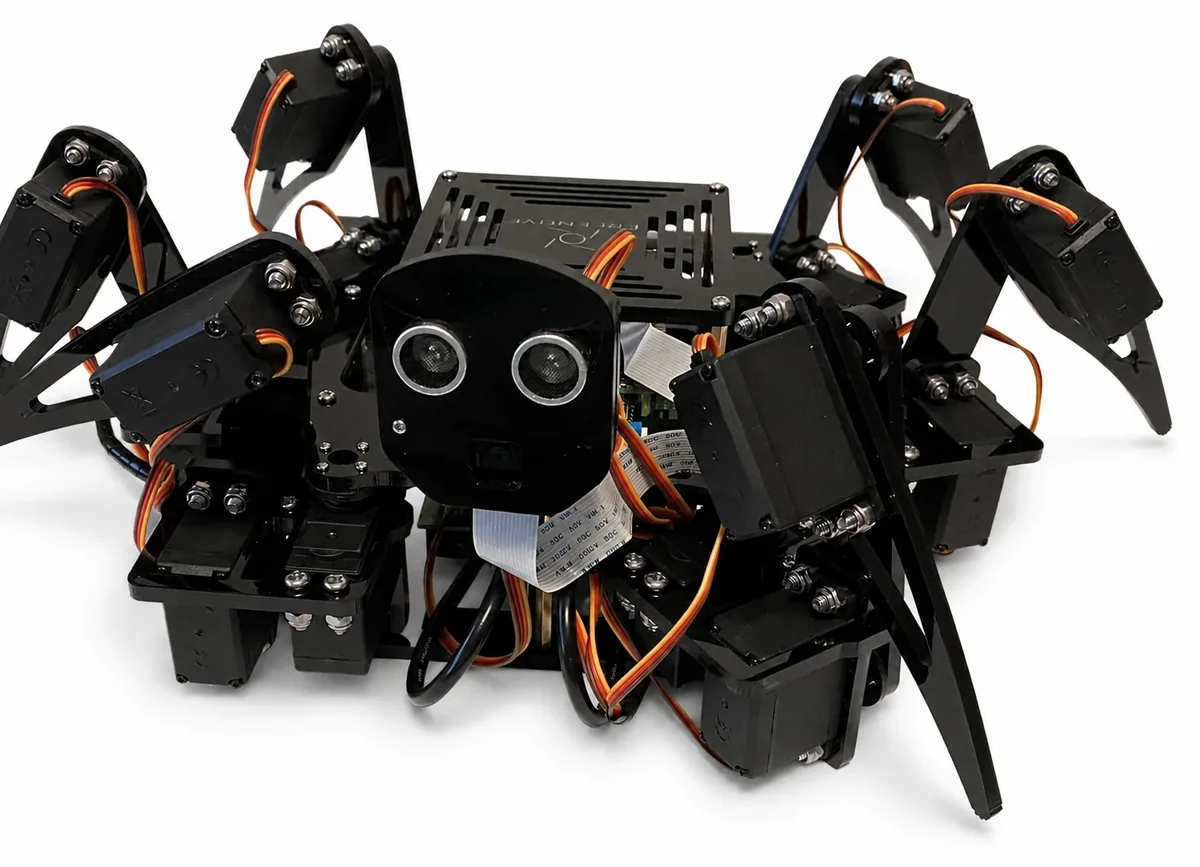
Provide a large hexapod platform for motion and robotics experiments.
This large Freenove hexapod provides a Raspberry Pi platform for motion and control experiments. It supports exploration of multi-legged robotics, treating movement stability as something to evaluate rather than a quantified performance claim.
A large Freenove hexapod platform based on Raspberry Pi.
Custom motion, control, and sensing prototypes for research, education, and industrial concept validation.
View detailsSend a structured brief so we can review the right path before sensitive details are shared.