What was the challenge?
Control a multi-jointed quadruped from a phone browser.
This quadruped combines 12 degrees of freedom with a web server accessed through a phone browser over Wi-Fi. It brings multi-joint movement and wireless interaction together, while specific gait behavior and performance depend on actual testing. This item appears in the portfolio under Robotics, with its documented challenge, solution and output presented on the page.
Discuss a similar project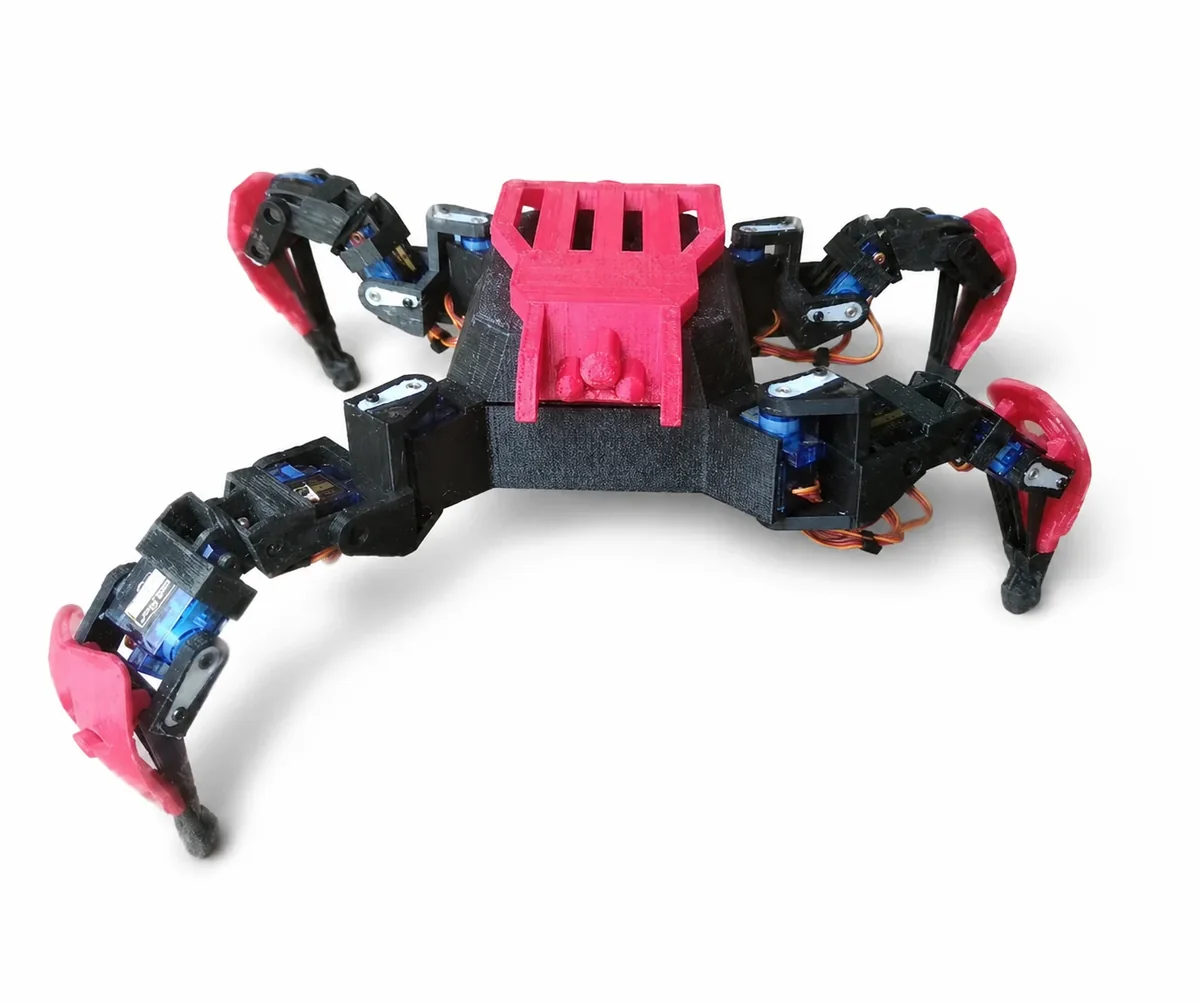
Control a multi-jointed quadruped from a phone browser.
This quadruped combines 12 degrees of freedom with a web server accessed through a phone browser over Wi-Fi. It brings multi-joint movement and wireless interaction together, while specific gait behavior and performance depend on actual testing.
A 12-degree-of-freedom quadruped with Wi-Fi control.
Circuits, controllers, sensors, and connectivity for measurable smart prototypes.
View detailsCustom motion, control, and sensing prototypes for research, education, and industrial concept validation.
View detailsSend a structured brief so we can review the right path before sensitive details are shared.