What was the challenge?
Execute arm-movement commands using a compact controller.
This arm connects a XIAO ESP32S3 board with servo-driven joints. The concept focuses on command execution through a compact controller, without assuming extra sensing or connectivity features solely from the board’s capabilities. This item appears in the portfolio under Robotics, with its documented challenge, solution and output presented on the page.
Discuss a similar project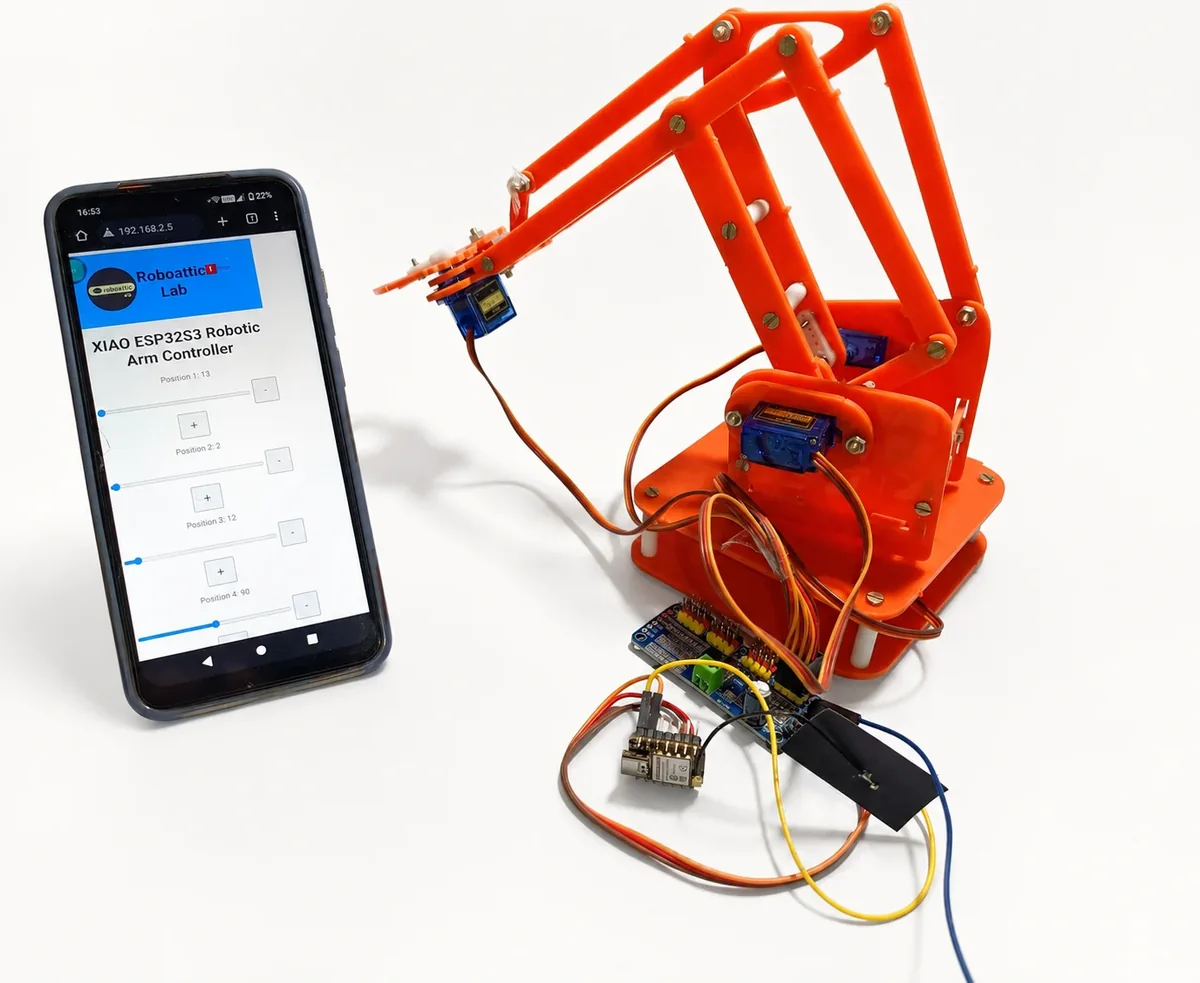
Execute arm-movement commands using a compact controller.
This arm connects a XIAO ESP32S3 board with servo-driven joints. The concept focuses on command execution through a compact controller, without assuming extra sensing or connectivity features solely from the board’s capabilities.
A servo-driven arm built around XIAO ESP32S3.
Circuits, controllers, sensors, and connectivity for measurable smart prototypes.
View detailsCustom motion, control, and sensing prototypes for research, education, and industrial concept validation.
View detailsSend a structured brief so we can review the right path before sensitive details are shared.