Robotics and Intelligent Systems · Intermediate
Automated Pick-and-Place Arm
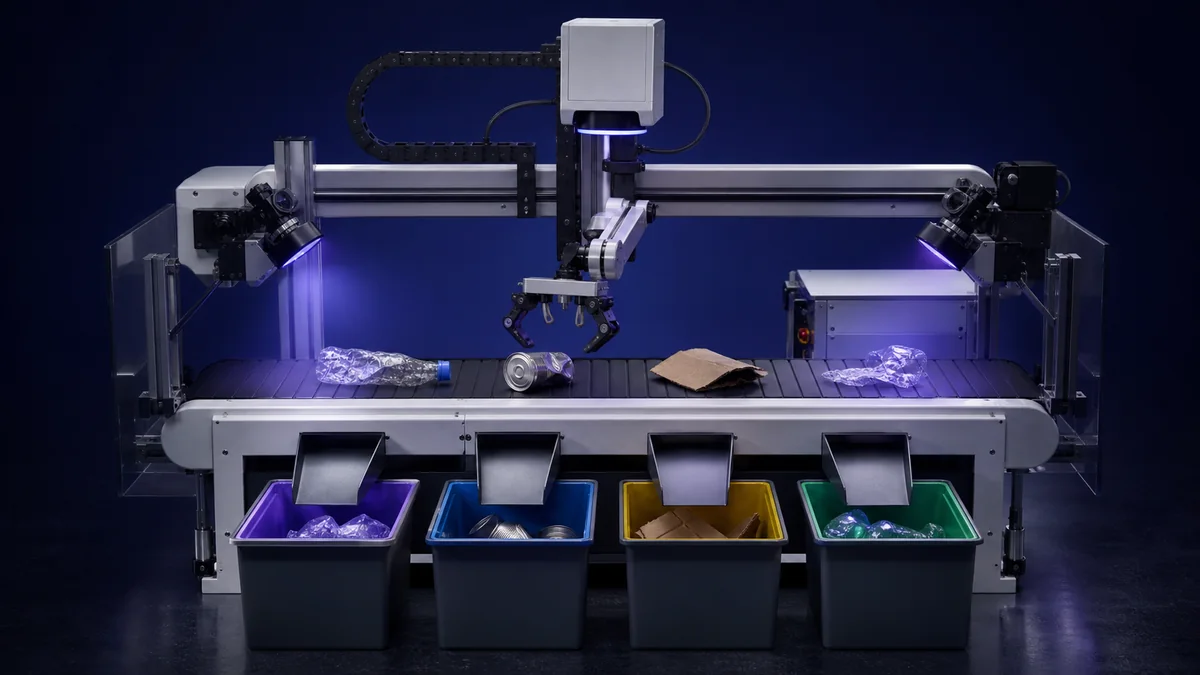
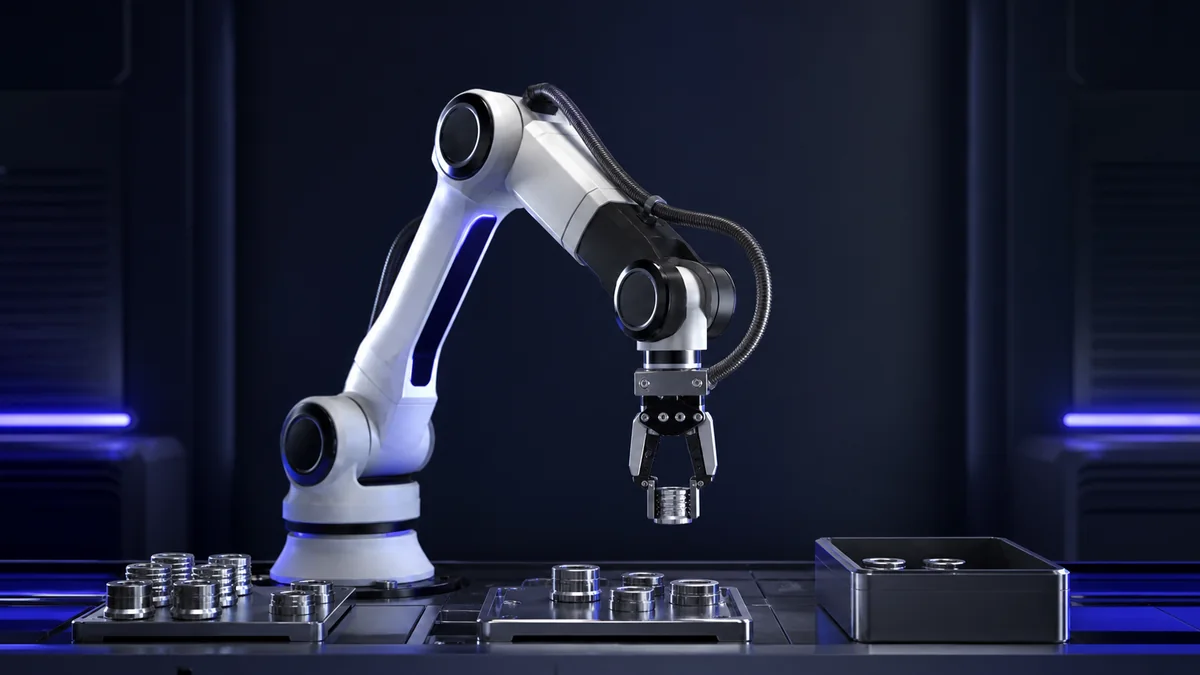
Automated Pick-and-Place Arm turns a defined need into a testable engineering concept. The proposed outcome is to pick defined parts and transfer them between repeatable positions with calibrated motion. The scope begins with requirements, operating conditions, and measurable acceptance criteria, then uses ROS 2, LiDAR, Motion planning where those tools fit the evidence. Expected outputs include editable design or source files, an evaluation-ready prototype or simulation, and documented findings for the next decision. This concept can be adapted for universities and schools according to dimensions, environment, materials, integration needs, and budget. It represents a project that can be designed and developed based on requirements, not a claim that an identical system has already been delivered.
A project that can be designed and developed based on requirements.
Concept and expected outcome
Pick defined parts and transfer them between repeatable positions with calibrated motion. Final architecture and components depend on dimensions, operating conditions, safety constraints, integration, budget, and the evidence required from the prototype.
Proposed scope
- A concise requirement brief for Automated Pick-and-Place Arm, including operating context and acceptance criteria.
- Editable engineering or source files plus the agreed prototype, simulation, or fabrication package.
- A bounded test that evaluates the central objective: Pick defined parts and transfer them between repeatable positions with calibrated motion.
- A short validation record covering evidence, limitations, and recommended next steps.
Suggested implementation path
- Confirm users, environment, interfaces, and constraints for Automated Pick-and-Place Arm.
- Select the smallest technical approach that can test the highest-risk assumption.
- Build and evaluate a bounded prototype against measurable criteria.
- Deliver the agreed files, test evidence, and a recommendation for iteration or production.
Information needed before work starts
Approximate dimensions, operating environment, quantities, existing files or interfaces, target budget, and acceptance criteria help define a responsible scope. Medical, safety-critical, industrial, or regulated uses require separately documented requirements, risk review, and appropriate validation before real-world use.
Request this project
Send the intended use and any available drawings, photos, or interface details so the scope can be reviewed.
Request this project